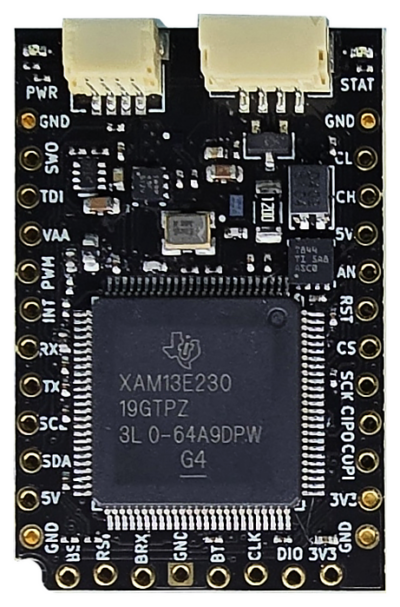
BeagleConnect Torque controller module, top view showing the microcontroller, CAN and Qwiic connectors, expansion pins, and debug connections.

BeagleConnect Torque

What is BeagleConnect Torque?

Bring real-time control, connected sensing and edge AI into your next design. BeagleConnect Torque is a compact, open-source controller module for developers, educators and embedded system designers building robots, motor controllers and CAN-connected devices. A Texas Instruments AM13E23019 microcontroller combines a 200 MHz Arm Cortex-M33 processor with dedicated math and neural-network acceleration, while onboard CAN hardware, Qwiic and expansion connections make it easy to connect your application.

At just 25.4 × 38.1 mm, BeagleConnect Torque brings the controller into your own hardware through a 100-pad solder-down interface. Use the same module to explore control algorithms, prototype a sensor or actuator node, and develop a custom carrier. Editable hardware designs, firmware sources and detailed connector references give you a starting point you can inspect, modify and build upon.

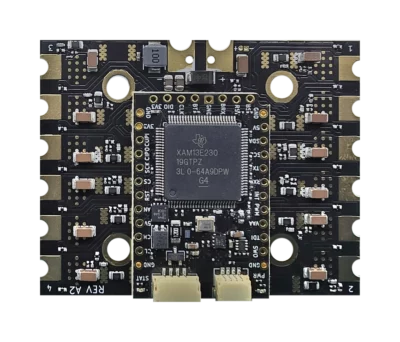
BeagleConnect Torque also provides the central controller for BeagleConnect QuadESC, coordinating four three-phase brushless DC motor channels. Pair BeagleConnect Torque with suitable external gate drivers, power transistors and application firmware to build your own motor-control system.

Build with BeagleConnect Torque

Explore robot joints and wheel drives, gimbals, pumps, fans, positioning systems and distributed sensor or actuator nodes. Combine timed outputs and synchronized measurements for control experiments, or develop local inference models for fault and anomaly detection. Field-oriented control, DroneCAN and AI diagnostics depend on your application firmware and connected hardware.

BeagleConnect Torque ships with TI’s ROM bootstrap loader. Load your application through CAN, I²C or UART using the TI bootloader protocol, or program and debug through Serial Wire Debug. The documentation includes TI XDS110 wiring and Code Composer Studio setup. Development targets community-aligned Zephyr and OpenOCD support; consult the current documentation for board and tool compatibility.
Chipset Features

Texas Instruments AM13E23019 real-time microcontroller

  • 200 MHz Arm Cortex-M33 processor with floating-point support
  • 512 KB flash and 128 KB SRAM
  • Trigonometric math unit for control calculations
  • TinyEngine neural-network accelerator for local inference
  • Three 12-bit analog-to-digital converters
  • Motor-control PWM resources with synchronization, dead-band control and ADC triggering
  • CAN FD, UART, I²C and SPI communication peripherals
  • Hardware capabilities for secure boot, secure debug, secure firmware updates and cryptographic acceleration
Board Features
  • Connected control: Onboard TCAN844 CAN transceiver, four-pin JST-GH CAN/power connector and software-selectable 120 Ω bus termination
  • Sensor expansion: Qwiic connector for 3.3 V I²C accessories
  • Flexible I/O: Two 12-pin expansion rows with UART, SPI, analog, PWM and control signals; refer to the module pinout for multiplexing and accessory connections
  • Analog acquisition: 30 assigned analog input pads through the carrier interface, with a separate carrier-supplied analog reference
  • Programming and debug: Eight-pin connection for Serial Wire Debug, UART, reset, boot selection, ground and 3.3 V debug power
  • Power: Nominal regulated 5 V carrier input, onboard 3.3 V regulation and automatic selection between carrier-derived and separate 3.3 V debug power
  • Carrier integration: 100-pad underside land-grid array at 1.27 mm pitch
  • Compact PCB: 25.4 × 38.1 mm outline; four-layer, 1.6 mm PCB

Supply regulated carrier power rather than raw battery voltage. Analog acquisition requires the separate analog reference, and CAN communication requires the transceiver’s 5 V supply. See the power guide when planning a carrier or debug setup.

Resources

Put your next design in motion. Start with the quick start guide, explore the open hardware, and build your own connected controller with BeagleConnect Torque.